FANUC AC Servo Software 90B3 / 90B7 Series Angle based Learning Control Specification Manual Additional Manual Page 2
Additional Manual
Title 90B3 / 90B7 Angle Based
Learning Control Specification Manual
Draw No.
A - 63639E - 119
01 ’04.02.23 K.Maeda Newly designed Sheet 02
Edit Date Design Description / 10
1. Overview
We have developed Angle based Learning control to usual Time based Learning control.
This function merit is the following.
• This function provides not time but angle as Learning period. Therefore this function can apply to variable
time period application that is difficult to realize by usual Time based Learning control. For example this
function can apply Learning control to Constant surface speed cutting etc.
• This function can start Learning control by not only usual "G05 (High-speed Cycle Cutting)" but also
"External starting signal". Then Learning control can be applied by NC program without making High-
speed Cycle data.
• Until now you select only discrete command speed as to provide time period. But you can select
continuous command speed as to provide angle period. For example this function can apply Learning
control to Gear cutting with Flexible synchronous control.
• There is no restriction on minimum rotation speed.
(Note) EGB control is not available in 90B3 or 90B7 series.
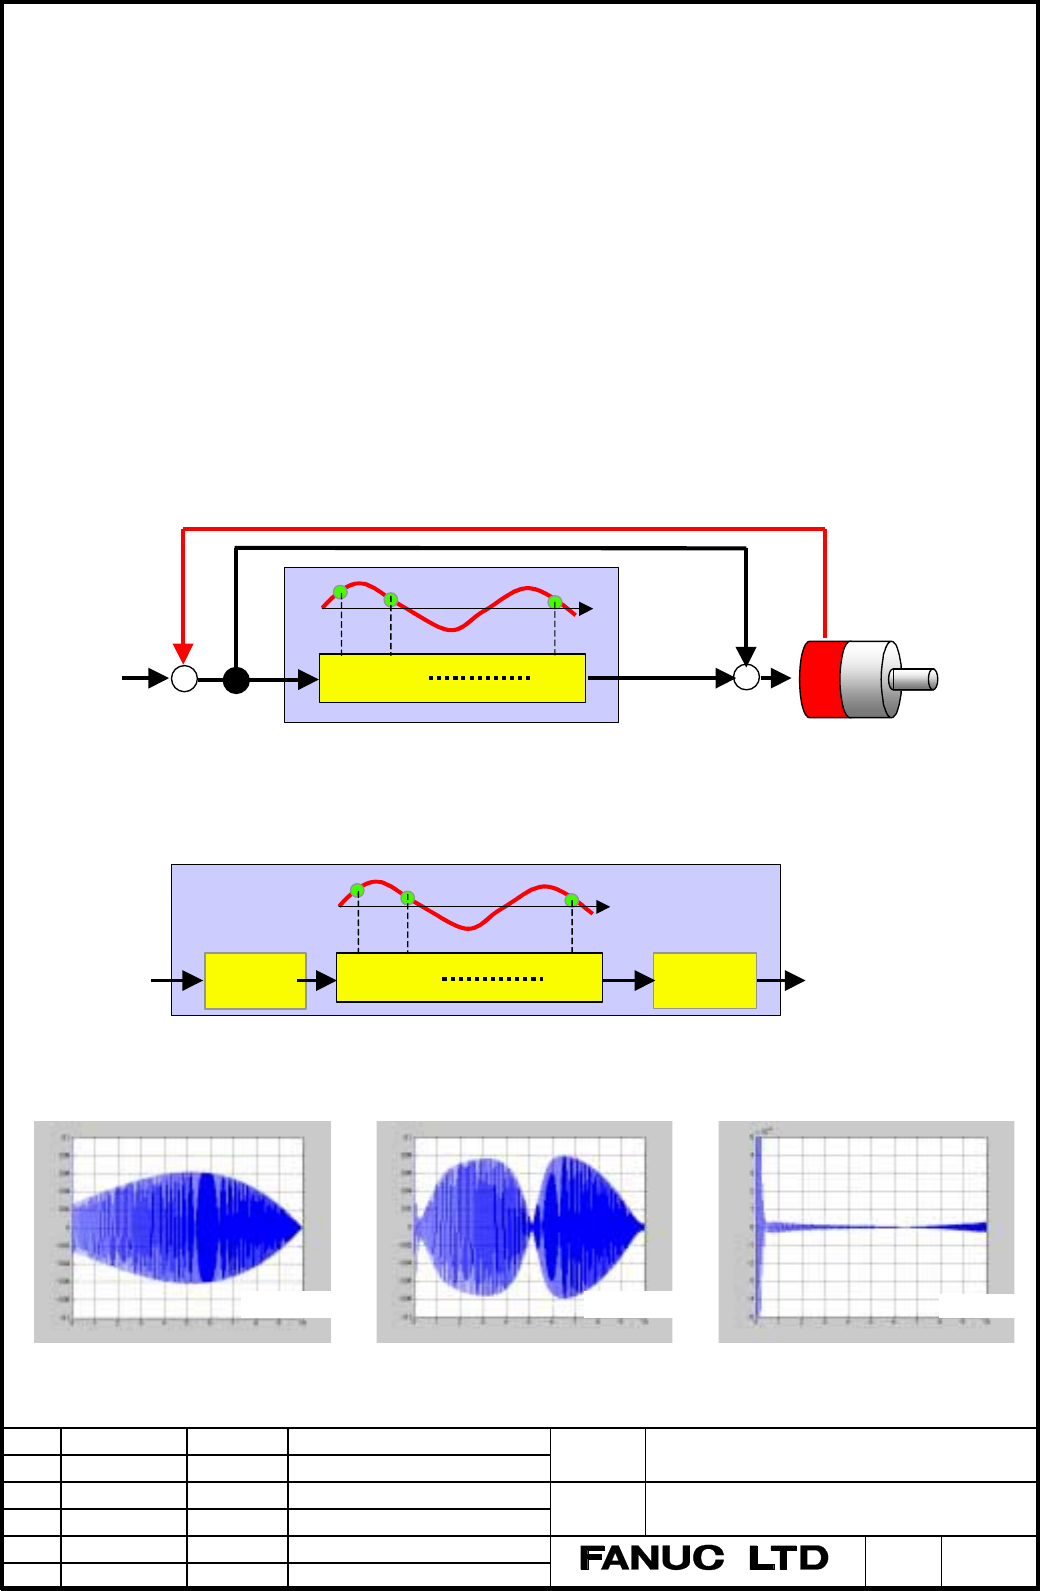
1-1. Difference between Time based and Angle based Learning controller
1) Time based Learning control
Usual (Time based) Learning control creates compensation data by referring to time. Then usual Learning
control can apply the only application with constant speed of spindle axis.
2) Angle based Learning control
Angle based Learning control creates compensation data by referring to angle. Then Angle based Learning
control can apply applications with variable speed of spindle axis.
•
••
• Position Error in case of Spindle speed changed from 600 min
-1
to 1800 min
-1
Without Learning Time based Learning control Angle based Learning control
20
µ
m/div
1
µ
m/div
20
µ
m/div
t1 t2
tn
Command
+
-
Error Compensation
Learning Controller
+
+
Feedback
θ
θθ
θ 1 θ
θθ
θ 2 θ
θθ
θ m
θ
θθ
θ Þ
ÞÞ
Þ tt Þ
ÞÞ
Þ θ
θθ
θ
Time Þ
ÞÞ
Þ Angle
Convert
Error
Compensation
Angle Þ
ÞÞ
Þ Time
Convert
Contents Summary of FANUC AC Servo Software 90B3 / 90B7 Series Angle based Learning Control Specification Manual Additional Manual
- Page 1FANUC AC SERVO SOFTWARE 90B3 / 90B7 Series Angle based Learning Control Specification Manual 1. Overview 2. Configuration 3. Application servo software series / edition 4. Parameters 5. PMC signals 6. Alarm (CAUTION) The contents of this manual may be changed as a result of improvements to the servo
- Page 21. Overview We have developed Angle based Learning control to usual Time based Learning control. This function merit is the following. • This function provides not time but angle as Learning period. Therefore this function can apply to variable time period application that is difficult to realize by
- Page 32. Configuration The start of Angle based Learning control are the usual way to synchronize the start of High-speed cutting (G05) and the new way to synchronize the start of PMC signal. It is necessary to refer to angle as a standard. You can select position feedback or position command as this refe
- Page 4You can apply Spindle Learning control with angle based to rotary axis. 2) Application example in Flexible Synchronous Control Synchronous shaving machine CNC Servo control or Spindle control FSC Learning Learning Master axis controller controller Command Kp Kp Position error Gear Ratio Reference Sl
- Page 53. Application servo software series / edition • 90B7 / 13(M) or later • 90B3 / 14 (N) or later (next edition planning) 4. Parameters Function bit #7 #6 #5 #4 #3 #2 #1 #0 2008 (FS16i ) SLEN 1952 (FS15i ) SLEN (#5) Learning control is (L-axis only) 0: not available. 1: available. (Option) #7 #6 #5 #4
- Page 6♦ Relation between Angle based Learning controller and Parameters N2243 N2244 Fx Delayed Memory Convert Convert Reference Position N2246 One rotation = N2241×N2242 N2247 Gx N2248 N2249 G05 or G320 + Position error + HRV control *1 Fx : Learning band. The higher you set Leaning band, precision is hig
- Page 7We suggest that you select minimum time period as the quotient of (Angle based Learning period) divided by (delayed memory number) is integer. 2244 (FS16i ) Learning frequency band 2657 (FS15i ) (Setting range) Case of sampling 1msec, from 0 to 350 Case of sampling 0.5msec, from 0 to 700 (Setting un
- Page 82250 (FS16i ) Delay compensation 2663 (FS15i ) (Setting range) from –32767 to +32767 (Plus is forward, Minus is delay) (Setting unit) nsec When reference to M-axis (M-axis : N2227#5 = 1), one sampling is delayed. Angle based Learning controller compensates sampling delay of reference position by thi
- Page 95. PMC signal If you input the following PMC signal, Angle based Learning control starts and finishes at point of any time without G05. This function can be used in Series 16i –B with supported General purpose DI/DO. #7 #6 #5 #4 #3 #2 #1 #0 G0320 SVDI08 SVDI07 SVDI06 SVDI05 SVDI04 SVDI03 SVDI02 SVDI
- Page 106. Alarm In case that there is a problem in parameter setting, the following "PARAMETER INCORRECT" displays. Alarm Parameter No. Parameter No. derail No. (FS15i ) (FS16i ) Cause Measures 2402 2241 Case that the quotient 1) Minimum time period is 2242 which divides Angle increased. based Learning per